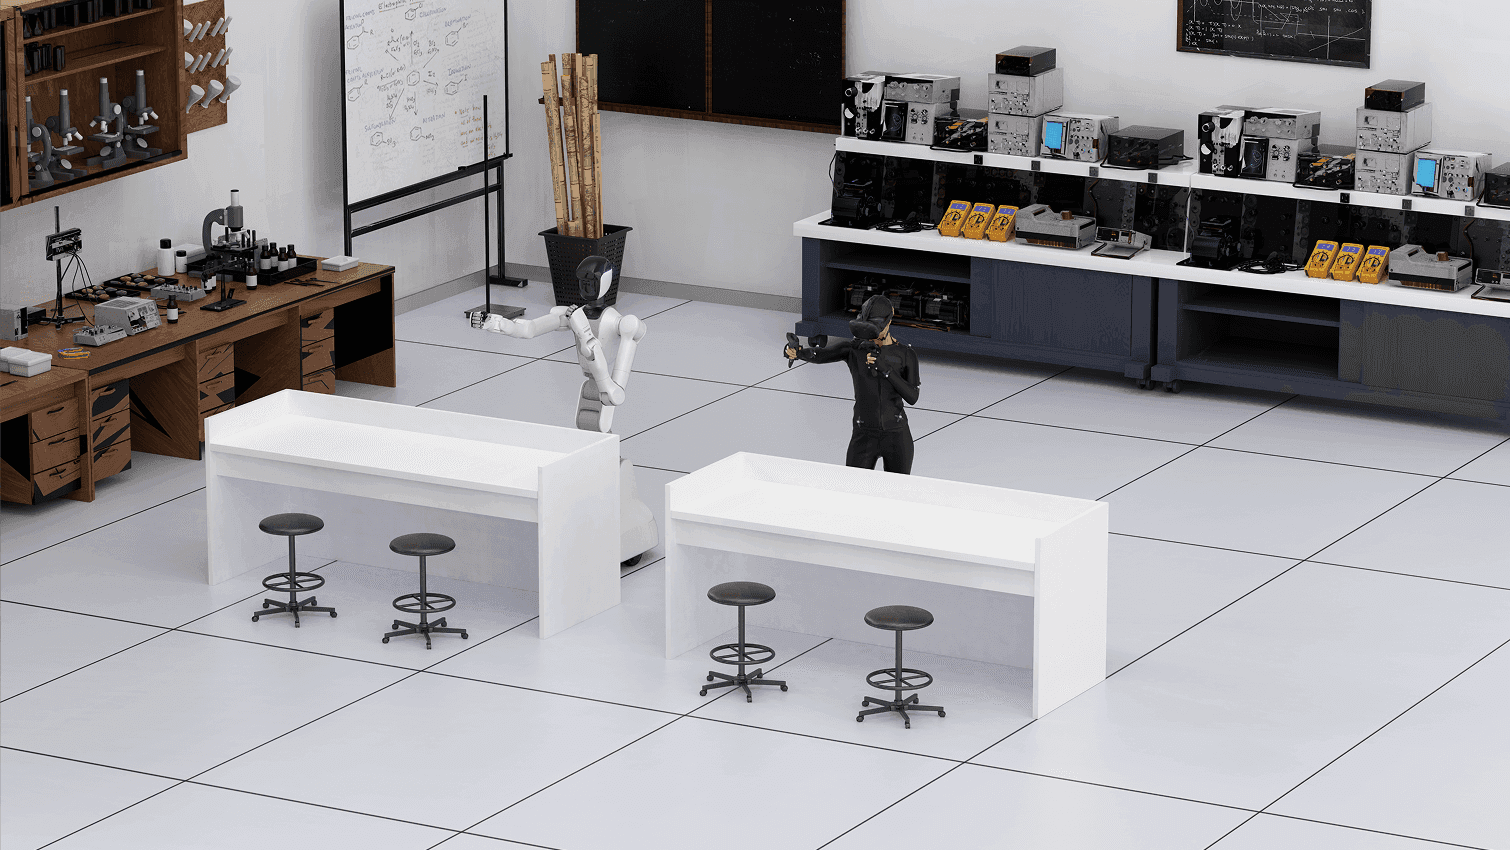
We present X2Real, an evolvable simulation benchmark for faithfully evaluating the real-world performance of robotic manipulation policies based on Nvidia Isaac Lab-Arena. Following three core principles (faithfulness, diversity, and fairness), X2Real calibrates simulation visual and physical properties to align with real hardware, achieving a 0.84 linear correlation between simulated and real-robot evaluation results. It features a comprehensive taxonomy with 10 capability dimensions and 44 hierarchical long-horizon tasks, covering basic manipulation skills and advanced capacities such as visual grounding, language understanding, and bimanual control. We further adopt multi-axis domain randomization and strictly disjoint training-evaluation pipelines to mitigate benchmark exploitation and ensure credible evaluation.
我们提出 X2Real:一个基于 NVIDIA Isaac Lab-Arena、可持续演进的仿真基准,旨在忠实评估机器人操作策略在真实世界中的表现。遵循保真性、多样性和公平性三项核心原则,X2Real 对仿真的视觉与物理属性进行校准,使其与真实硬件保持一致,仿真与真实机器人评估结果之间的线性相关系数达到 0.84。该基准构建了全面的任务分类体系,涵盖 10 个能力维度和 44 项具有层级结构的长时程任务,既覆盖基础操作技能,也涵盖视觉指代定位、语言理解和双臂协同控制等高级能力。此外,我们采用多维度域随机化,并严格分离训练与评估流程,以减少针对基准的投机优化,确保评估结果可信。
2026.10.13
A pair of co-designed, three-finger, nine-DoF dexterous manipulation interface: one wearable for data collection, one for robot deployment.
2026.09.02
A generative world model for action-controllable, long-horizon robotic simulation. Built on next-scale autoregression with scale-compressed streaming memory and on-policy alignment, it generates visual futures in a coarse-to-fine manner, achieving calibrated task outcomes and consistent policy rankings across 600+ matched sim-to-real closed-loop rollouts.
2026.08.27
A training-free framework that enables robots to acquire new manipulation skills in seconds from a single human video while retaining previously mastered capabilities.
2026.08.03
A multimodal action tokenizer that doubles as a semantic interface between vision-language reasoning and continuous robot control.
2026.06.30
XRZero-G0 is an embodied data acquisition and strategy learning system designed through deep collaboration between hardware and software. It aims to overcome the fundamental bottleneck of acquiring high-quality, motion-aligned demonstration data in the field of dexterous robot operation.
2026.06.10
Carving World Action Modeling at Their Event Joints
2026.05.29
fully open-source, trained with gradient-bridged co-training, and deployable on real robots straight from pretraining.
2026.05.28
An end-to-end embodied foundation model that leverages large-scale multimodal pretraining to achieve (1) embodiment-aware vision--language understanding, (2) strong language--action association, and (3) robust manipulation capability.
2025.09.08
自变量机器人致力于研发由端到端大模型驱动的通用机器人,聚焦具身大模型的通用性与泛化能力,是国内具身智能基础模型的标杆企业,
2026年发布全球首个世界统一模型,并自主研发、持续优化原生适配基础模型控制的机器人本体。
公司自研“数据采集-大模型算法-核心零部件-硬件本体”,实现全栈闭环,目前已率先在家庭、
物流等真实场景实现通用具身智能技术的落地,
长远目标是构建能够精细操作的通用智能机器人。
关于我们
全球首个基于世界统一模型架构的具身智能基础模型WALL-B
世界统一模型架构(World Unified Model)
从“VLA“到”原生多模态融合架构“,单模型适配全模态,全任务
原生多模态与本体感
物理世界规律的理解与零样本泛化
主动交互与自我进化
新一代通用轮式仿人形机器人
了解详情通用轮式双臂机器人
QUANTA X1 PRO
新一代具身轮式仿人形机器人
QUANTA X2
高自由度仿人五指灵巧手
ArtiXon Hand
围绕自研的 WALL-A 操作大模型,实现从感知、理解到动作控制的全流程智能统一,
彻底突破传统机器人依赖规则与编程的局限。实现复杂环境中的高精度、自主化作业。